
What is a Point Cloud?
A point cloud is a set of discrete measurement points in three-dimensional space. Each point has at least three coordinates (X, Y, Z) describing its exact position – and often additional attributes such as RGB color values, intensity, return number, or classification code.
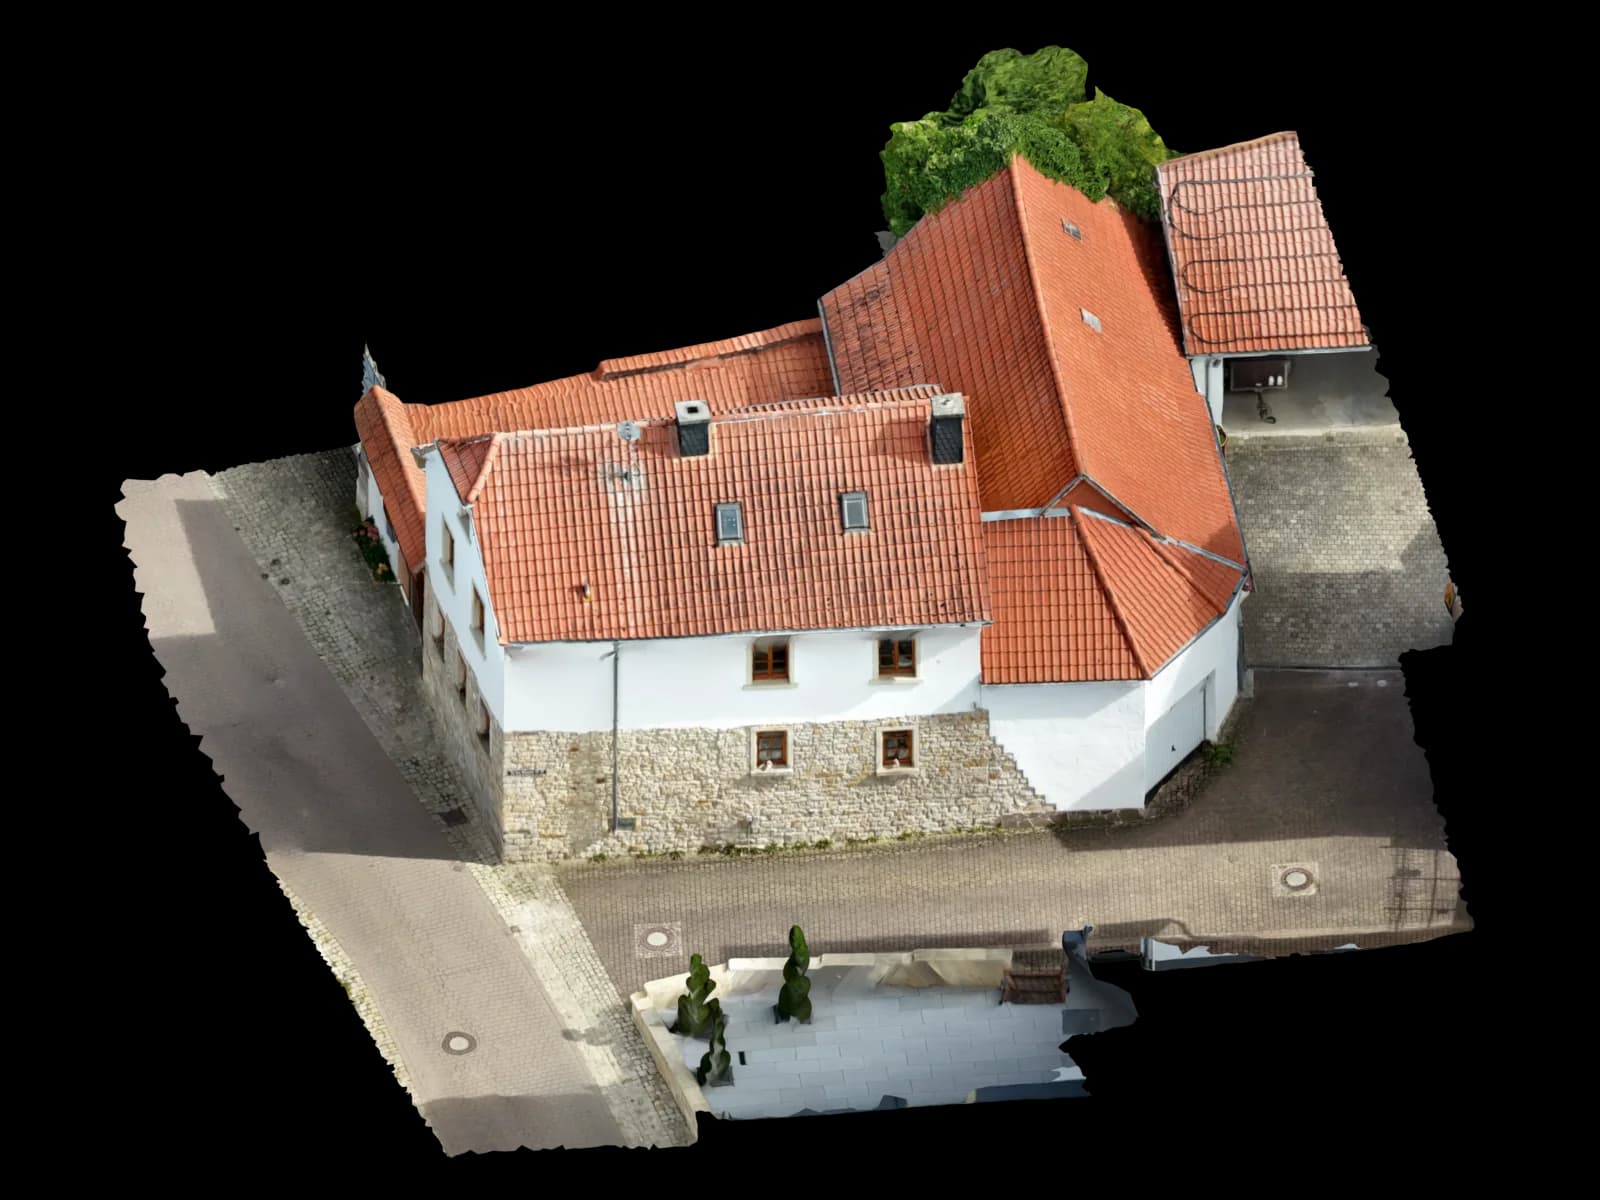
In drone photogrammetry, a point cloud is not created by direct measurement, but by mathematical reconstruction from overlapping aerial images. The result is a georeferenced cloud of data that maps the surface of the surveyed terrain, building, or object in three dimensions.
Point clouds are the central raw data output of photogrammetry: from them, Digital Terrain Models (DTM), Digital Surface Models (DSM), orthophotos, meshes, CAD plans, and BIM models are derived. Anyone wanting to understand how drone data flows into planning must understand the point cloud as a starting point.
Important: photogrammetric point clouds differ from LiDAR point clouds. While LiDAR actively emits laser pulses and measures their travel time, photogrammetry is based purely on image processing. This affects density, accuracy, and applicability – especially in areas with little texture or vegetation.
Creation: SfM/MVS Process
The creation of a photogrammetric point cloud runs in two main phases: Structure from Motion (SfM) and Multi-View Stereo (MVS). Both processes are now fully automated in photogrammetry software such as Agisoft Metashape, Pix4Dmapper, DJI Terra, and RealityCapture.
Structure from Motion (SfM) analyzes overlapping images and searches for common image points – so-called keypoints. Algorithms such as SIFT (Scale-Invariant Feature Transform) or ORB identify distinctive points in each image and match them across all shots. From the parallax shift of these points between images, the algorithm calculates the relative camera position of each shot and produces an initial, very sparsely populated point cloud (Sparse Cloud).
Multi-View Stereo (MVS) densifies this Sparse Cloud into a Dense Cloud. For each pixel in the image, 3D coordinates are calculated by simultaneously evaluating the match between multiple image pairs. The result is a dense point cloud with typically 50 to over 500 points per square meter – depending on flight altitude and GSD.
Georeferencing is done either via RTK/PPK (directly via GNSS receiver on the drone) or via Ground Control Points (GCPs) measured before the flight. Without georeferencing, a relative point cloud is created, but not with absolutely correct positional accuracy in the national coordinate system.
Important flight parameters for a high-quality point cloud: at least 70% longitudinal and 60% lateral image overlap, uniform lighting without hard shadows, a GSD of ≤ 3 cm for surveying purposes, and for buildings, supplementary oblique shots, as vertical nadir images cover vertical surfaces (facades) poorly.
Quality Parameters: Density, Noise & Accuracy
The quality of a point cloud can be assessed using three key parameters: point density, noise, and absolute positional accuracy.
Point Density (points per m²): Density indicates how many points per square meter exist in the point cloud. At a GSD of 2 cm and standard overlap (70%/60%), 100–300 points/m² are typically achievable. With increased overlap (80%/70%) or cross-grid flights, values of 300–500 points/m² are possible. For roof surveys, 100 points/m² is sufficient; for Scan-to-BIM models with LOD 300 detail, 200–500 points/m² is recommended.
Noise: Photogrammetric point clouds inherently have more noise than LiDAR data. On textured surfaces (roof tiles, paving), noise is low – typically ±1–3 cm. On smooth, uniform surfaces (white facades, metal roofs), SIFT algorithms find fewer keypoints, leading to greater noise or gaps.
Positional Accuracy (RMSE): Absolute accuracy is the most important parameter for surveying applications. With RTK-GNSS and a high-quality drone such as the DJI Phantom 4 RTK or Matrice 350 RTK, the following values are achievable: ±2–3 cm horizontal, ±3–5 cm vertical. With GCPs and PPK, in favorable conditions ±1–2 cm horizontal and ±2–4 cm vertical are achievable. These values correspond to the commonly cited rule of thumb: horizontal accuracy ≈ 1× GSD, vertical accuracy ≈ 1.5–3× GSD.
Note: these accuracies apply to open areas with correct GCP distribution. In valleys, under tree canopy, or in windy conditions with poor GNSS reception, values can deteriorate significantly.
Formats: LAS/LAZ, E57, RCP/RCS, PLY, XYZ
Choosing the right format is critical for the downstream workflow. Depending on the target software, file size, and interoperability requirements, different formats are recommended.
LAS / LAZ (LASer Format, ASPRS Standard): LAS is the dominant binary format for geospatial point clouds, maintained by the American Society for Photogrammetry and Remote Sensing (ASPRS). The current version is LAS 1.4 (R15). LAS stores X/Y/Z coordinates, intensity, return number, and ASPRS classification codes. LAZ is the lossless compression of LAS using the LASzip algorithm – reducing file size by 70–80%.
E57 (ASTM Standard): E57 is a vendor-neutral exchange format standardized by ASTM International under ASTM E2807. Originally developed for terrestrial laser scanning, it also works well for photogrammetric point clouds. E57 contains coordinates, colors, and scanner metadata.
RCP / RCS (Autodesk Recap): RCP is the native project format of Autodesk Recap, optimized for AutoCAD, Revit, and Civil 3D workflows with LOD streaming. LAS/LAZ or E57 can be converted to RCP via Autodesk Recap.
PLY and XYZ/PTS: PLY is a simple format with RGB colors, useful for visualization but without georeferencing. XYZ/PTS is plain ASCII text – universally readable but very large files with no metadata.
| Format | Type | File size | Strength | Software |
|---|---|---|---|---|
| LAS / LAZ | Binary / compressed | LAZ: 70–80% smaller than LAS | Geospatial, ASPRS standard, full metadata | AutoCAD Civil 3D, ArcGIS, QGIS, CloudCompare |
| E57 | Binary (ASTM E2807) | 40–60% smaller than ASCII | Interoperability, archiving, scanner metadata | Autodesk Recap, Leica Cyclone, FARO Scene |
| RCP / RCS | Autodesk native | Internally optimized (LOD) | Smooth performance in Autodesk tools | AutoCAD, Revit, Civil 3D, Navisworks |
| PLY | Binary or ASCII | Large (no compression) | Simple, RGB colors, web viewers | CloudCompare, Blender, Meshlab, Web viewers |
| XYZ / PTS | ASCII text | Very large | Universally readable, no special tool needed | Excel, Python, QGIS, text editors (small files) |
ASPRS Classification per LAS 1.4
A raw Dense Cloud does not distinguish between ground, building, or vegetation – all points have the same status. ASPRS classification assigns a class code to each point, defined in the LAS 1.4 specification and coded from 0 to 255.
The most important standard classes for construction are: Class 0 – Never Classified (raw), Class 1 – Unclassified, Class 2 – Ground, Class 3 – Low Vegetation (≤ 0.5 m), Class 4 – Medium Vegetation (0.5–2 m), Class 5 – High Vegetation (> 2 m), Class 6 – Building, Class 7 – Low Point/Noise, Class 9 – Water, Class 17 – Bridge Deck.
Filtering on Class 2 (Ground) produces the Digital Terrain Model (DTM) – free of buildings and vegetation. Including all classes (2 + 3–6) produces the Digital Surface Model (DSM). This separation is fundamental for PV planning, hydrology, and urban planning.
Classification is performed automatically in photogrammetry software using algorithms such as Progressive Morphological Filter (PMF) or Cloth Simulation Filter (CSF). For precise results – such as Scan-to-BIM – manual post-processing in CloudCompare or Recap is often needed after automatic classification.
Applications in CAD, BIM, GIS & PV Planning
The point cloud is the universal starting point for all downstream steps in drone photogrammetry. Depending on the project and target format, different derivatives are created.
Roof Surveying & PV Planning: From the point cloud, a 3D roof model is derived as a mesh (OBJ, IFC) or as vector surfaces (DXF/DWG). These models can be directly imported into PV planning software such as PV*SOL Premium, Pvsyst, or Eturnity. The point cloud is used for precise roof area calculation, ridge height, and slope measurement.
As-Built Survey & Scan-to-BIM: The point cloud is imported directly into Revit (via Autodesk Recap RCP) or ArchiCAD (via E57). Planners reference floor plans, sections, and elevations directly from the point cloud and create BIM-compliant models (IFC 2x3 / IFC 4). This process is called Scan-to-BIM.
DTM / DSM: Through classification and TIN interpolation from Class 2 points, the DTM is created. It is the basis for volume calculation per VOB/C DIN 18300, drainage planning, terrain profiles, and site plan representation.
CAD Plans & As-Built Documentation: In AutoCAD Civil 3D, BricsCAD, or QGIS, the point cloud can be projected directly as a reference underlay. Vector lines are drawn manually or automated feature extraction algorithms extract building edges, eave lines, and dormers as DXF/DWG layers.
| Application | Format chain | Software | Main benefit |
|---|---|---|---|
| Roof Surveying / PV Planning | LAZ → OBJ / DXF | Metashape, Pix4D → PV*SOL, Eturnity | Precise roof area, ridge, slope |
| Scan-to-BIM (Revit) | E57 / RCP | Autodesk Recap → Revit | IFC models from existing buildings |
| DTM / DSM | LAZ (Class 2) → GeoTIFF | Metashape, QGIS, ArcGIS | Terrain model for planning & hydrology |
| CAD As-Built Plan | LAZ → DXF / DWG | PointCab, Civil 3D, CloudCompare | Automatic edge detection, layering |
| Volume Calculation (Civil) | LAZ / LAS | Trimble BC, Civil 3D, Pix4Dmatic | VOB/C-compliant volume calculation |
Software Ecosystem: Create, Process, View
The software ecosystem for point clouds is divided into three phases: creation (from drone images), processing (classification, denoising, format conversion), and application (viewer, CAD, BIM, GIS).
Creation (SfM/MVS Software): Agisoft Metashape (€179–€3,499), Pix4Dmapper (subscription), DJI Terra (free for DJI drones, limited), RealityCapture (pay-per-input, GPU-accelerated), OpenDroneMap (open source, AGPL-3.0).
Processing & Analysis: CloudCompare (open source, powerful for comparison, classification, analysis), LAStools by rapidlasso GmbH (de-facto standard for LAS/LAZ processing), PDAL (open source Python library for batch processing), PointCab Origin (commercial, automatic floor plan extraction from point clouds).
Viewers: Autodesk Recap (free viewer + RCP import), Potree (open source WebGL viewer for large point clouds in browser), CloudCompare, Leica Cyclone VIEWER (free for E57), FARO WebShare (cloud-based, E57).
CAD & BIM Integration: Revit (RCP via Autodesk Recap), AutoCAD / Civil 3D (RCP + LAS natively), ArchiCAD (E57 import), MicroStation (LAS/LAZ natively), QGIS (LAZ via PDAL natively), ArcGIS Pro (LAS/LAZ natively).
Practical Tips & Common Mistakes
Mistake 1: Too low image overlap. The most common cause of gaps in the point cloud is insufficient overlap. Minimum: 70% longitudinal and 60% lateral. On texture-poor surfaces (snow, grass, flat roofs), 80%/70% or a cross-grid flight pattern is recommended.
Mistake 2: No or poor georeferencing. A point cloud without georeferencing has no absolute coordinates and cannot be integrated into national coordinate systems. Always use RTK or at least 3–5 GCPs evenly distributed across the project area.
Mistake 3: Wrong coordinate system. Germany uses ETRS89/UTM (EPSG:25832 for Zone 32N, EPSG:25833 for Zone 33N). Ensure your photogrammetry software exports the correct reference system. AutoCAD and Revit have their own coordinate system settings that must be configured separately.
Mistake 4: Too much noise on texture-poor surfaces. White walls, metal roofs, and still water generate few SIFT keypoints, resulting in noisy point clouds. Solution: supplementary close-range shots from different angles, increased overlap, or LiDAR for these areas.
Mistake 5: Missing classification before DTM export. Never export a DTM from an unclassified point cloud. Building and vegetation points create false elevations in the DTM. Always classify first and export the DTM from Class 2 points only.
Tip: For Scan-to-BIM projects, use cross-grid flights plus supplementary facade flights in horizontal direction. This creates even point clouds also on facades and vertical edges, which are often poorly covered by pure nadir flights.