
The Three Pillars: GSD, Overlap, and Altitude
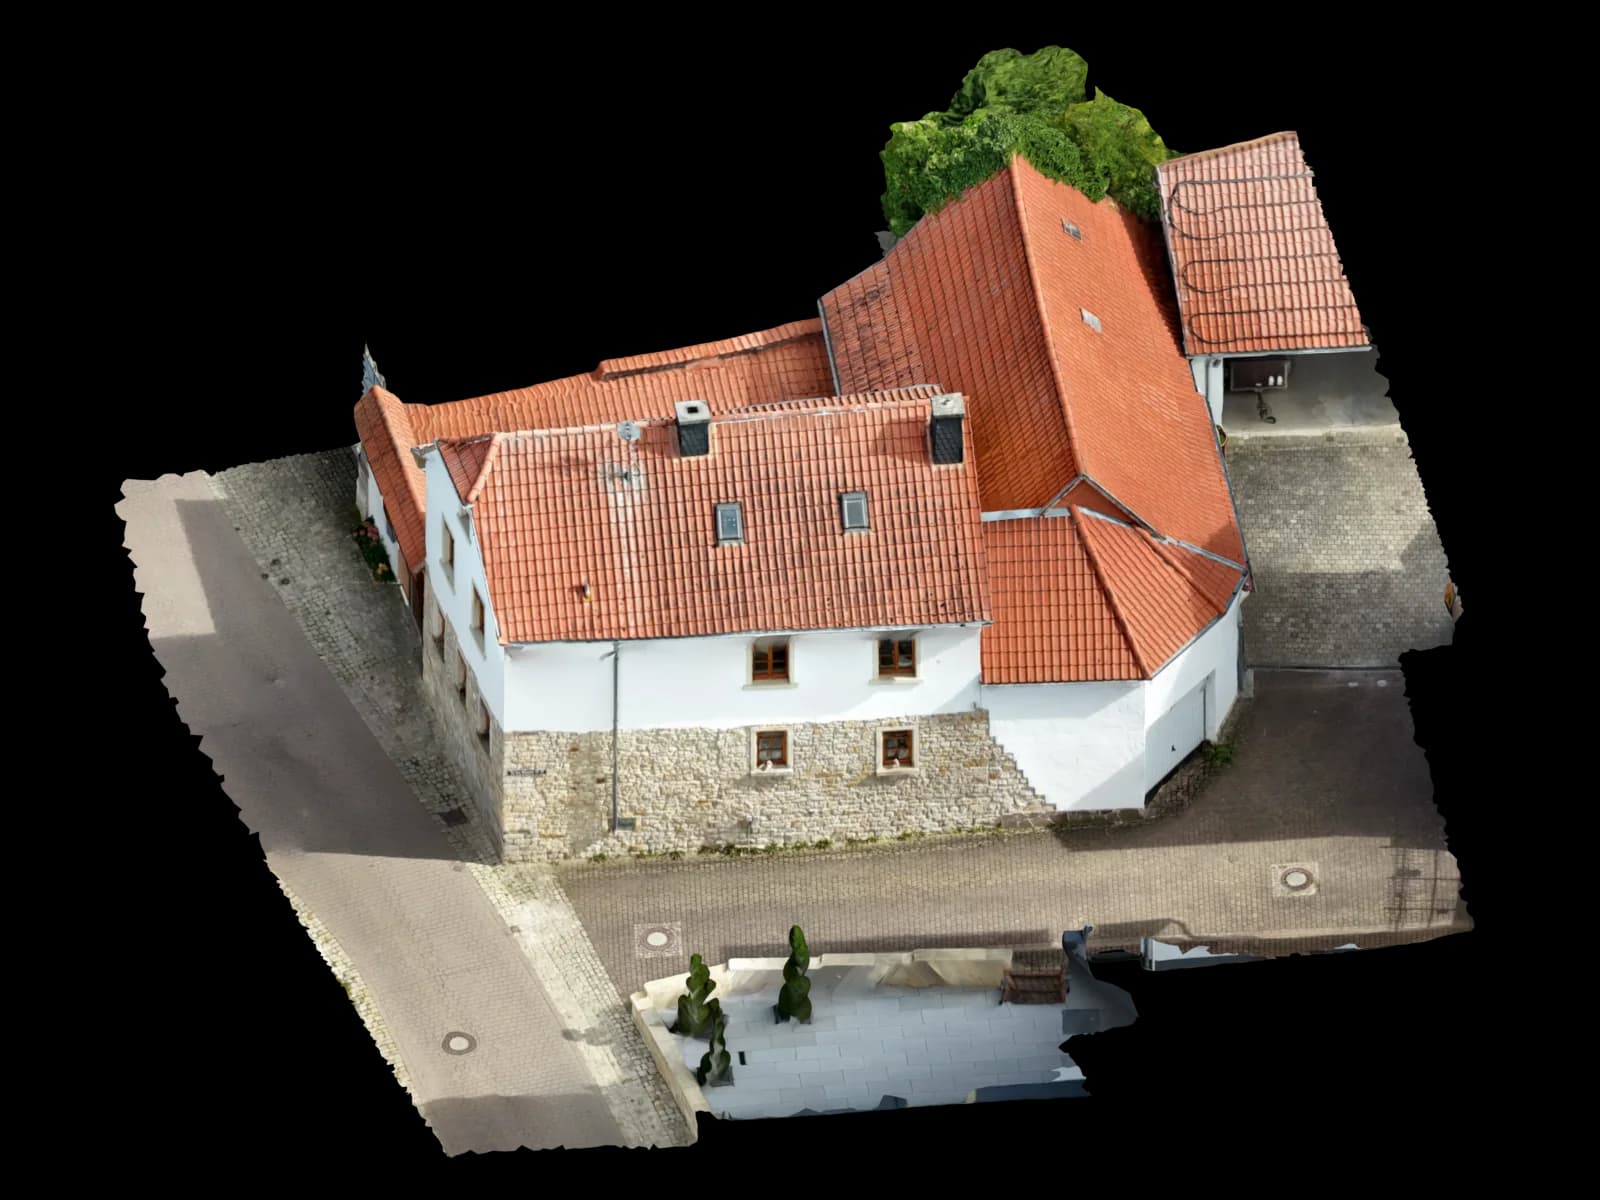
A drone photogrammetry mission is not simply a flyover – it is a precisely defined image acquisition sequence whose quality is determined by three interdependent parameters: Ground Sampling Distance (GSD), image overlap, and flight altitude. These three form a triangle: changing one automatically affects the others.
GSD describes the ground pixel size of a camera sensor from a given altitude. A GSD of 2 cm means each image pixel covers 2 × 2 cm on the ground. The formula is: GSD [cm/px] = (altitude [m] × pixel size [µm]) / (focal length [mm] × 10). For a DJI Mavic 3 Enterprise sensor (1/2 inch, 5.6 µm pixel size, 24 mm focal length equivalent), a flight altitude of 60 m yields approximately 1.4 cm GSD.
Image overlap describes what percentage of two adjacent images show identical content. It splits into frontlap (along the flight direction) and sidelap (perpendicular to it). Overlap determines how many images capture every ground point from different angles – critical for depth reconstruction in photogrammetry software.
All three parameters are linked via camera settings (trigger interval, sensor format, focal length) and flight speed. Good mission planning software like Pix4Dcapture, DJI GS RTK, or UgCS automatically calculates the required trigger interval and track spacing once GSD and overlap are specified.
Frontlap and Sidelap: Correct Values for Each Mission Type
Frontlap describes how far two consecutive images overlap along the flight path. At 80% frontlap, each new image shows 80% of the previous image area – the drone produces significantly more images per distance. Sidelap describes the same perpendicular to the flight direction: at 70% sidelap, adjacent flight lines overlap 70% of their width.
Why is overlap necessary? Photogrammetry software (Structure from Motion, SfM) can only calculate a stable 3D model if every ground area is visible in at least 5–9 images from different angles. This is called Multi-View Stereo (MVS). Insufficient overlap leads to holes in the model or the inability to connect adjacent images (tie point gaps).
Standard mapping (orthophoto, elevation model, flat terrain): 75–80% frontlap, 60–70% sidelap. These are the proven starting point for flat or gently sloped surfaces like fields, construction sites, or flat roofs.
Complex 3D models (buildings, pitched roofs, facades): 80–85% frontlap, 70–75% sidelap. The more height variation and vertical surfaces, the more overlap is needed. Pitched roofs, dormers, and chimneys benefit from high redundancy.
Vegetation, wind, poor lighting: ≥ 85% frontlap, ≥ 75% sidelap. When trees, moving vegetation, or poor texture (snow, water, uniform surfaces) hinder feature detection, higher overlap is the most effective countermeasure.
Flight Patterns: Grid, Double Grid, Oblique, and Corridor
The flight pattern determines from which directions and angles the camera captures the subject. Four fundamental patterns are relevant for photogrammetry, often combined:
| Pattern | Description | Use case | Overlap (F/S) |
|---|---|---|---|
| Grid Flight | Parallel flight lines over the area, camera straight down (nadir) | Orthophotos, elevation models, flat terrain, fields, construction sites | 75 % / 65 % |
| Double Grid | Two perpendicular grid flights, second pass rotated 90° | 3D models of buildings, complex roof geometry, precise surveys | 80 % / 75 % |
| Oblique Flight | Camera tilted 45°–75°, often as cross-pattern with 4–5 directions | Facade capture, building 3D models with walls, urban modeling | 70 % / 70 % |
| Orbit (Circle) | Drone flies circles around the object with tilted camera | Single buildings, towers, chimneys, facade details, presentation models | Manual / 60–70 % |
| Corridor (Linear) | Long narrow strip along a route or road | Roads, railways, pipeline routes, landslides, embankments | 80 % / 70 % |
Terrain Following: Maintaining Constant GSD on Slopes
On flat ground, a drone maintaining constant barometric altitude keeps a uniform GSD. On sloped terrain – hillsides, quarries, spoil heaps – ground clearance varies dramatically: flying 60 m above the starting point, the drone may be only 20 m above a steeply rising slope. The result: blurry images, variable GSD values, and unreliable accuracy.
Terrain Following solves this: mission planning is based on a digital elevation model (DEM) loaded into the flight app. The software calculates the flight path to maintain a constant clearance above the terrain, not above the starting point. The result is a uniform GSD across the entire survey area, even on slopes of 30°–40°.
For DACH projects, two DEM sources are practical: public elevation models from land surveying offices (e.g. DGM1 from LfU Bavaria, Swisstopo for Switzerland) – usually free or low-cost – and a preliminary coarse mission (GSD ~10 cm, low overlap) to generate an initial DEM for the precise follow-up flight.
Important when importing a DEM into mission planning software: the model must be in WGS84/EPSG:4326 coordinate system or the software must support transformation. The geoid separation must also be accounted for – the difference between ellipsoidal GPS height (WGS84) and physical height above sea level. In Germany this ranges from 35–50 m and is critical for correct altitude calculation.
Drone Mission Planning Step by Step
Structured mission planning avoids the most common mistakes and ensures the data is complete and processable on the first flight:
Define project goal and accuracy requirements
Orthophoto for documentation? GSD 3–5 cm is sufficient. Roof survey for PV planning? GSD ≤ 2 cm and RTK/PPK needed. The goal determines all subsequent parameters. Also identify the output format (DXF, DWG, OBJ, GeoTIFF) and target software (PV*SOL, Revit, AutoCAD) upfront.
Prepare area and elevation model
Draw the survey area in mission planning software. For terrain following: import DEM (land survey office or OpenDEM). Plan safety clearance to obstacles. Add a 15–25 m buffer around the target object for the drone approach and exit path.
Calculate GSD and flight altitude
Set target GSD (e.g. 2 cm). Enter camera parameters (focal length, sensor size, pixel count). Altitude is calculated automatically: AGL = (GSD × focal length × sensor_width_px) / (pixel_size_µm × sensor_width_mm × 10). Or set GSD directly in the app.
Choose overlap and flight pattern
Simple orthophoto: 75/65%, grid flight. Roof survey 3D: 80/75%, double grid. Facade: oblique 45°, 70/70%. Windy conditions or poor texture: +5–10% buffer on both axes. Check flight duration and image count – plan battery splits if needed.
Plan lighting and weather
Best light: overcast sky or flat sun angle (2 hours after sunrise, 2 hours before sunset). Hard midday shadows create poor feature areas in roof valleys and corners. Keep wind below 8 m/s (Beaufort 4) for stable images. Avoid rain, snow, or haze.
Calibrate camera and place GCPs (if no RTK)
Without RTK/PPK: place at least 5 ground control points (GCPs) at the edges and center of the survey area and measure with GNSS rover. With RTK/PPK: GCPs are optional but recommended as check points. Set camera to manual exposure: ISO 100–200, shutter speed ≥ 1/1,000 s.
Fly the mission and check data quality
After the flight, immediately review images: motion blur, incomplete coverage, gaps at edges? Check histogram: over- or underexposure in more than 10% of images indicates wrong exposure settings. If in doubt, re-fly the affected area before packing up.
Mission Planning Software Compared
The right mission planning software depends on the drone, terrain, and desired automation level. Here are the key options for professional photogrammetry missions:
| Software | Vendor | Platform | Terrain following | Drones | Price |
|---|---|---|---|---|---|
| Pix4Dcapture Pro | Pix4D | iOS / Android | Yes (via DEM import, Pix4D Cloud) | DJI Mavic 3E/T, Phantom 4 Pro, Matrice 300 RTK, Parrot Anafi | From €58/month (Pix4D subscription) |
| DJI Pilot 2 | DJI | Android (DJI RC Pro) | Yes (DJI Terra DTM import) | DJI Enterprise series (Matrice, Mavic 3E/T, Phantom 4 RTK) | Free (for DJI Enterprise) |
| DroneDeploy | DroneDeploy Inc. | iOS / Android / Web | Yes (automatic via Cloud DEM) | DJI series (broad), Autel, Skydio | From approx. €299/month |
| UgCS | SPH Engineering | Windows / Mac (Desktop) | Yes (local DEM import, SRTM) | DJI, Yuneec, Autel, Freefly, ArduPilot | From €66/month or one-time purchase |
| DJI GS RTK | DJI | Android (DJI Smart Controller) | Yes (DEM import) | DJI Phantom 4 RTK, Matrice 300 RTK | Free (for supported drones) |
| Litchi | VC Technology | iOS / Android | No (fixed AGL altitude) | DJI consumer series (Mavic, Mini) | One-time approx. €25 |
Common Planning Mistakes and How to Avoid Them
Mistake 1: Sidelap too low. The most common error in practice: sidelap below 60% saves battery capacity but leads to faulty orthophotos with visible stripes or gaps at strip edges. Recommendation: never below 60% sidelap, at least 70% for 3D models.
Mistake 2: Auto exposure. Auto-ISO and auto-shutter produce inconsistently bright images – a problem that manifests as color errors, poor tie points, and uneven textures in photogrammetry. Set manual exposure before the flight and verify with a test image.
Mistake 3: No height buffer with terrain following. DEM data has inaccuracies and does not include vegetation or temporary obstacles. Without a height buffer (at least 10–15 m above the profile), collision risk is real. Always plan extra clearance on unfamiliar terrain.
Mistake 4: Hard midday sun. Harsh shadows at near-vertical sun angle create deep black areas in roof valleys, chimneys, and building corners. Photogrammetry software struggles with feature extraction there. Overcast weather or early/late in the day delivers significantly better results.
Mistake 5: No area buffer. When the mission area is set exactly to the roof or plot boundary, edge images lack the needed overlap context. The drone needs 20–30 m extra approach distance at the boundary to achieve full overlap. Always plan 15–25 m buffer around the target object.
Recommendations by Use Case
Roof survey for PV planning (single-family home): Double grid, altitude 40–60 m, GSD 1.5–2 cm, overlap 80/75%, RTK or PPK. Optional oblique shots of dormers and facades. Result: millimeter-accurate 3D roof model for PV*SOL, Eturnity, or PVcase. Typical flight time: 12–18 minutes.
Commercial/industrial flat roof (1,000–10,000 m²): Simple grid is sufficient – no complex geometry. GSD 2–3 cm, overlap 75/65%, altitude 80–100 m. Flight time: 10–25 minutes depending on size.
Construction site documentation and progress monitoring: Grid flight with terrain following (spoil heaps, changing terrain), GSD 3–5 cm, overlap 75/65%. Regular repeat flights with identical mission path for as-built comparison. Flight time: 15–40 minutes.
Facade capture and building 3D model: Combination of vertical double grid (roof) and oblique shots (45°–60° for facades). GSD 1–2 cm for detail capture. 2–3 flights may be required depending on building size. Orbit mode as supplement for single buildings.
Terrain survey (slopes, quarries, landfills): Terrain following mandatory. Pre-load DEM (land survey office, OpenDEM). Overlap 80/75% due to vegetation blur. RTK or GCPs for accuracy. Pattern: grid or corridor depending on terrain shape.