
When existing photos are enough
Voxelia does not sell drone flights here. The service is the conversion of image sets into usable 3D data for planning, CAD, BIM, PV, and as-built workflows. That is why the first question is not which device captured the photos, but whether the image set is reconstructable.
Across established photogrammetry pipelines, the logic is the same: overlapping images are used to identify common features, estimate camera poses, and reconstruct dense geometry. COLMAP explicitly describes this as processing overlapping images of the same object from different viewpoints.
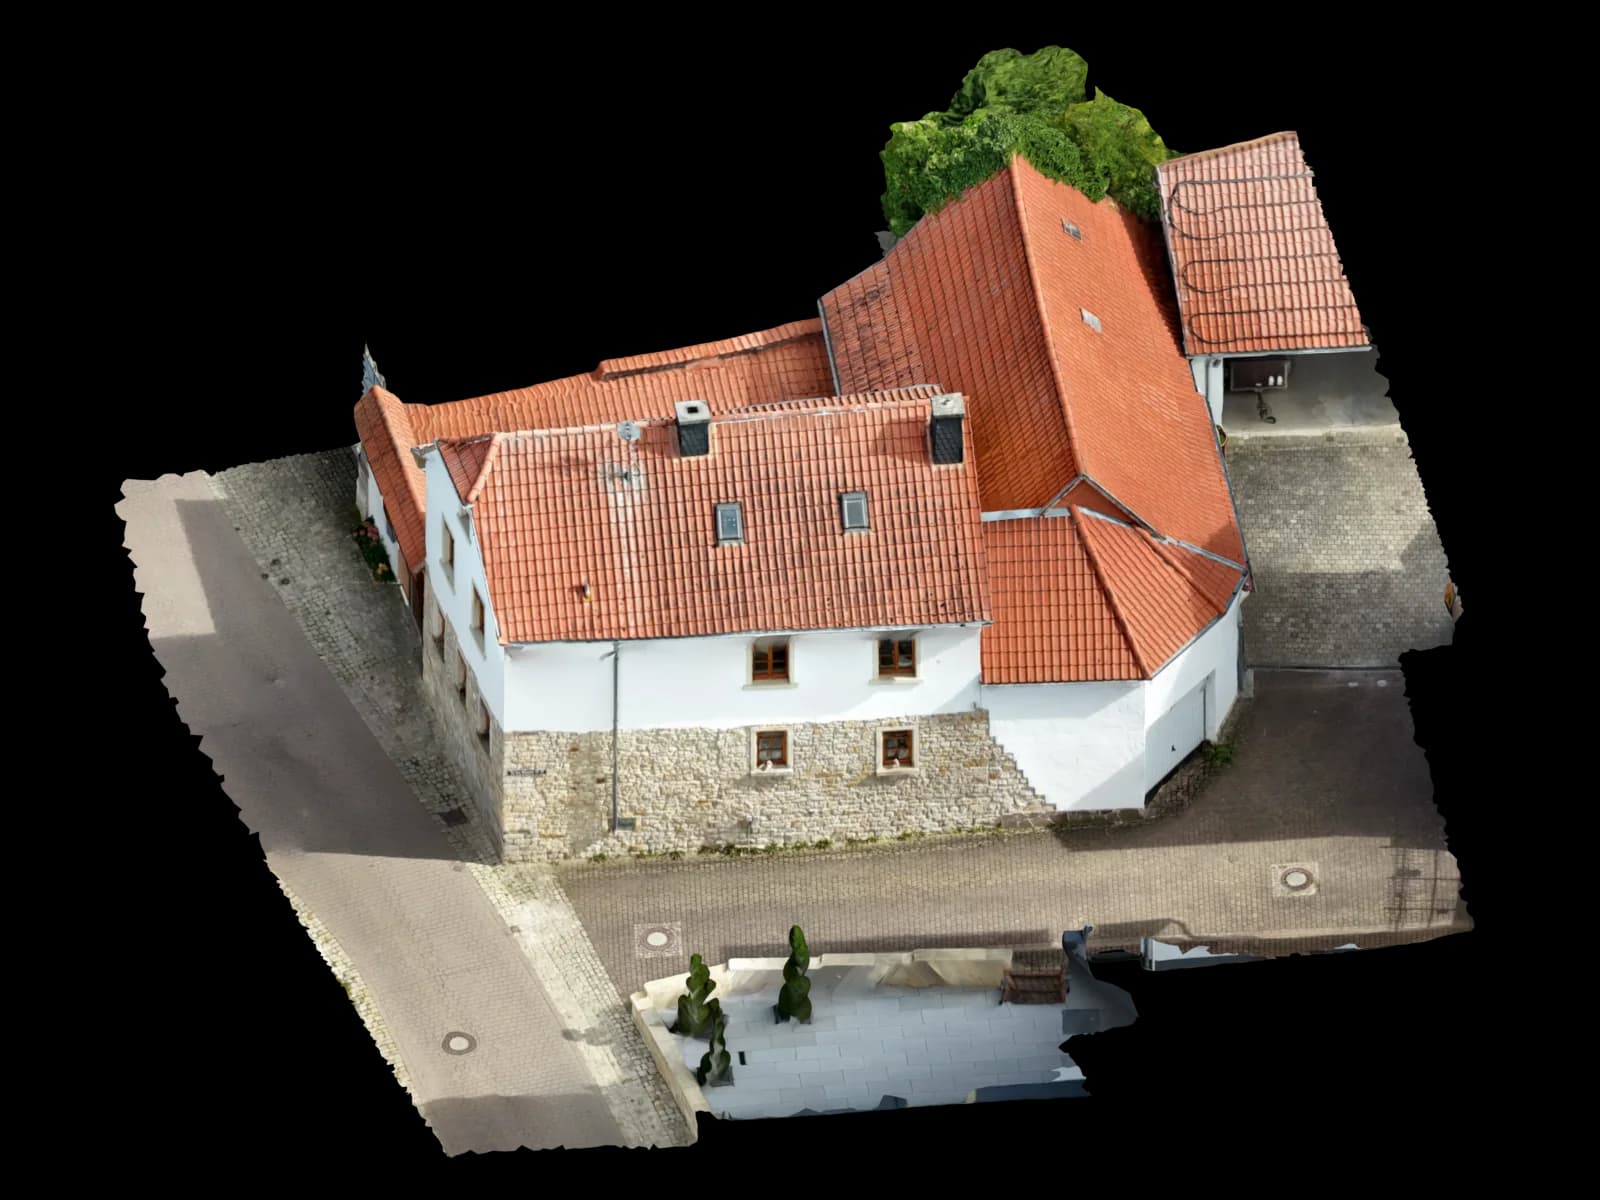
In practice, that means a single beauty shot is almost never enough. A properly captured circular object set, a documented facade, a roof with enough top-down and oblique coverage, or a structured archive of building photos can work very well.
Which image sources work well
Pix4D explicitly states that its software can process images from any capture app as long as image quality and overlap are sufficient. That matters for Voxelia because smartphone, DSLR, mirrorless, drone, or mixed datasets can all be valid inputs.
What matters more than the device is the capture behavior: consistent viewpoint steps instead of random shots, visible surface detail instead of blank areas, and enough relationships between neighboring images.
| Image source | Suitability | Best for | Practical note |
|---|---|---|---|
| Smartphone photos | Good to very good for small to medium objects and facade sections | Component details, interiors, smaller as-built sets | Works well when captured as a deliberate sequence rather than a few isolated snapshots. |
| DSLR / mirrorless camera | Very good | Technical as-built work, facades, objects, high-quality textures | Agisoft recommends fixed lenses around 20 to 80 mm equivalent for many close-range scenarios. |
| Existing drone imagery | Very good when overlap and viewpoints are suitable | Roofs, sites, facades, orthophoto bases | For classic nadir mapping cases, Pix4D gives 75% front overlap and 60% side overlap as a minimum reference. |
| Video frames | Conditional | Fast documentation or supplementary coverage | COLMAP recommends down-sampling the frame rate instead of flooding the project with near-identical frames. |
| Mixed archive photos | Conditional to good | Renovation, damage documentation, historical records | Can work if enough connected viewpoints exist across the set. |
Technical minimum requirements
COLMAP recommends good texture, similar illumination, high visual overlap, and changing viewpoints instead of only rotating the camera. RealityScan similarly states that each part of the scene should be visible in at least two high-quality images and that viewpoint changes should stay gradual.
Agisoft adds practical capture guidance: sharp images are a prerequisite, low ISO helps reduce noise, stable lighting supports alignment, and reflective or transparent surfaces should be avoided where possible.
For existing datasets, the quick check is simple: are the images sharp, consistently lit, and connected by enough intermediate viewpoints? If not, the chance of a technically usable model drops fast.
What usually breaks reconstructions
Typical failures are surprisingly simple: not enough intermediate images, blur, blank walls, reflections, rapidly changing lighting, or huge viewpoint jumps.
RealityScan explicitly warns that low overlap, weak texture, blur, and perspective changes that are too large can lead to multiple components or unaligned images.
| Problem | Why it matters | Typical symptom | Countermeasure |
|---|---|---|---|
| Textureless, transparent, or reflective surfaces | Stable image features are missing | Holes, fragmented meshes, disconnected components | Add structured views, use diffuse light, or switch to a different data basis where needed |
| Motion blur or shallow depth of field | Features become too soft for robust matching | Failed alignment or unstable geometry | Remove problematic frames and prefer sharp source images |
| Large jumps between viewpoints | Neighboring images share too little information | Several separate components | Add intermediate views and close loops |
| Changing exposure, backlight, hard reflections | The same object points look too different across images | Weak alignment and unstable texturing | Limit the set to consistent lighting phases where possible |
| Mixed zoom levels or extreme wide angles | Calibration and distortion handling become harder | Edge distortion and unstable camera solutions | Keep series as homogeneous as possible |
How the Voxelia delivery works
When a dataset is suitable, the fastest path is often to process what already exists instead of reshooting everything. A structured intake makes it possible to decide early whether a mesh, point cloud, orthophoto, or CAD-ready export is realistic.
Quick qualification of the image set
We check overlap, sharpness, viewpoints, and surface structure to see whether the images are usable in full or only in parts.
Define the target output
We clarify whether you need a 3D model, point cloud, orthophoto, viewer asset, or exports for CAD, BIM, or PV planning.
Clean the dataset
Blurred, duplicate, or highly inconsistent images are removed before reconstruction.
Validate alignment quality
The key question is whether the relevant images land in a stable single component without critical gaps.
Optimize geometry for the use case
The goal is not polygon excess, but a reliable deliverable for planning or presentation.
Deliver the file in the right format
Outputs are prepared to match the actual downstream workflow.
Which outputs can be created from suitable photos
If the dataset is strong enough, it can support several output types: textured 3D models, point clouds, orthophoto derivatives, or prepared exports for CAD, BIM, and PV workflows.
For Voxelia, the important part is that the result is not only visually impressive in a viewer but usable in the planning chain. That is why output definition happens before processing.
If you already know which format your downstream team needs, our CAD & orthophoto services and export format pages are the next logical step.